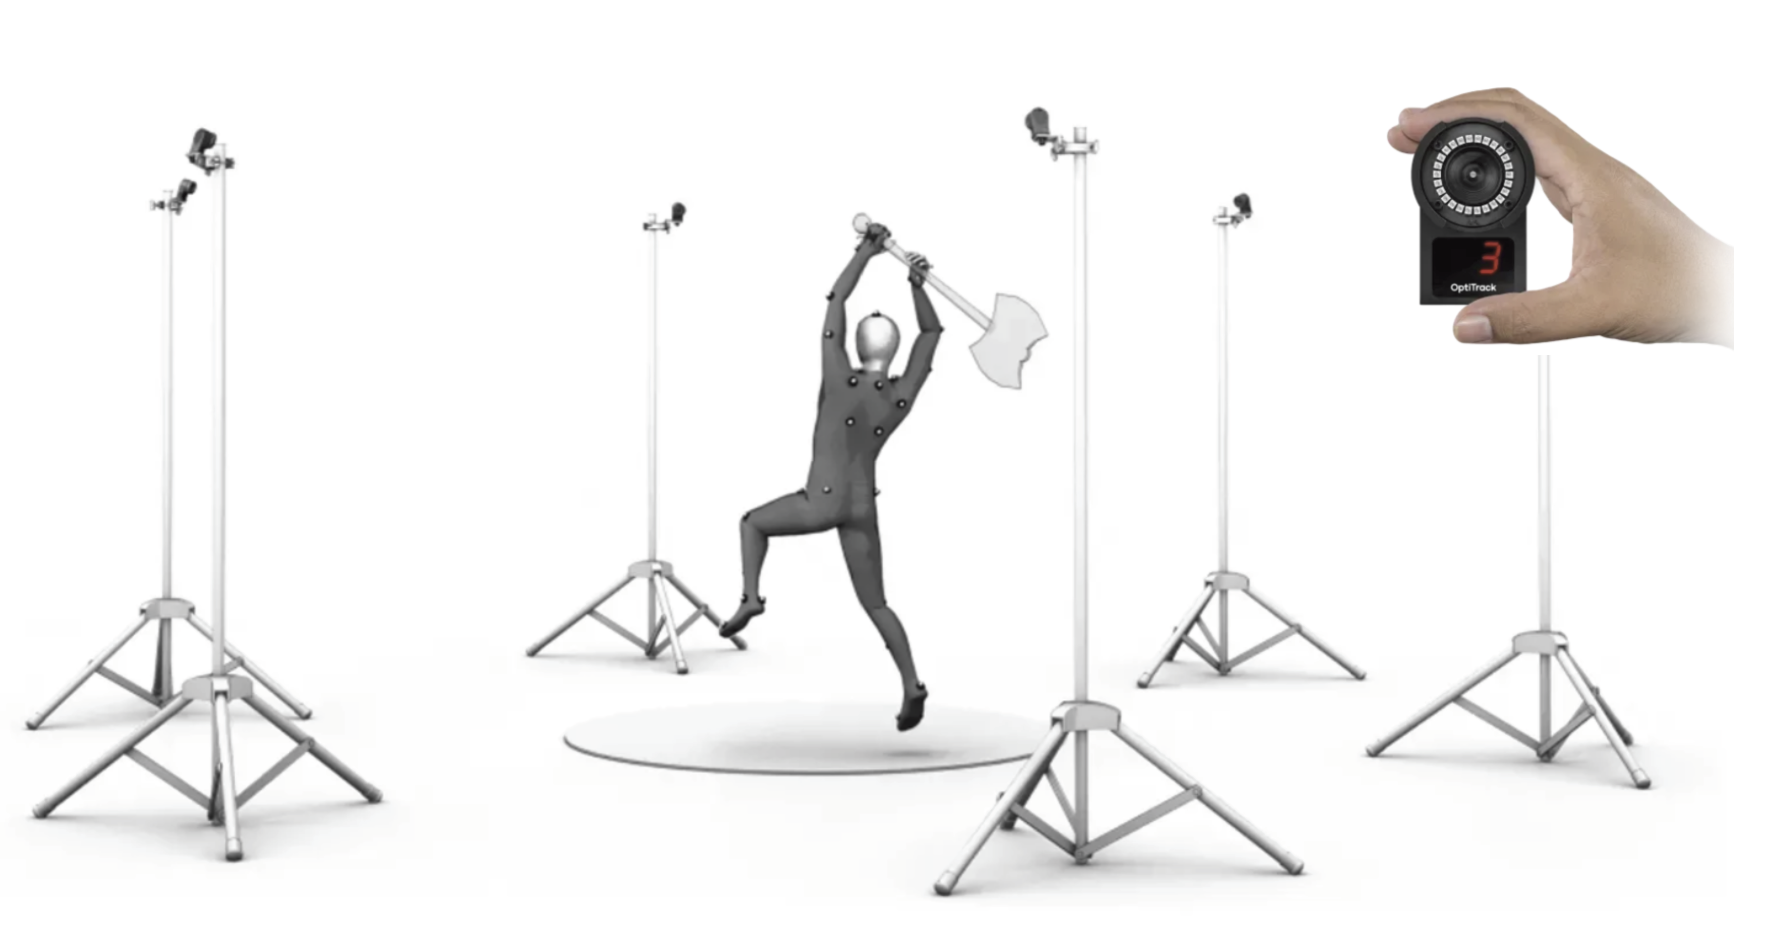
Facilities
Our lab develops and uses robotic systems, customized devices, and shared equipment for research in soft robotics, actuation, sensing, control, and robot characterization. This page summarizes the main facilities currently available in the lab.
Robots and Devices

5 Segment Robot
A modular cable-driven soft robotic arm for studying multi-segment actuation, shape sensing, modeling, and control.

3 Segment Robot
A slender tendon-driven continuum robot with embedded IMUs for proprioceptive shape estimation and closed-loop control.
Customized Devices

TCA Machine
An automated fabrication platform for producing twisted and coiled actuators with controlled manufacturing parameters.

HARP Machine
An open-source fabrication platform for helical anisotropic reinforced polymer actuators.
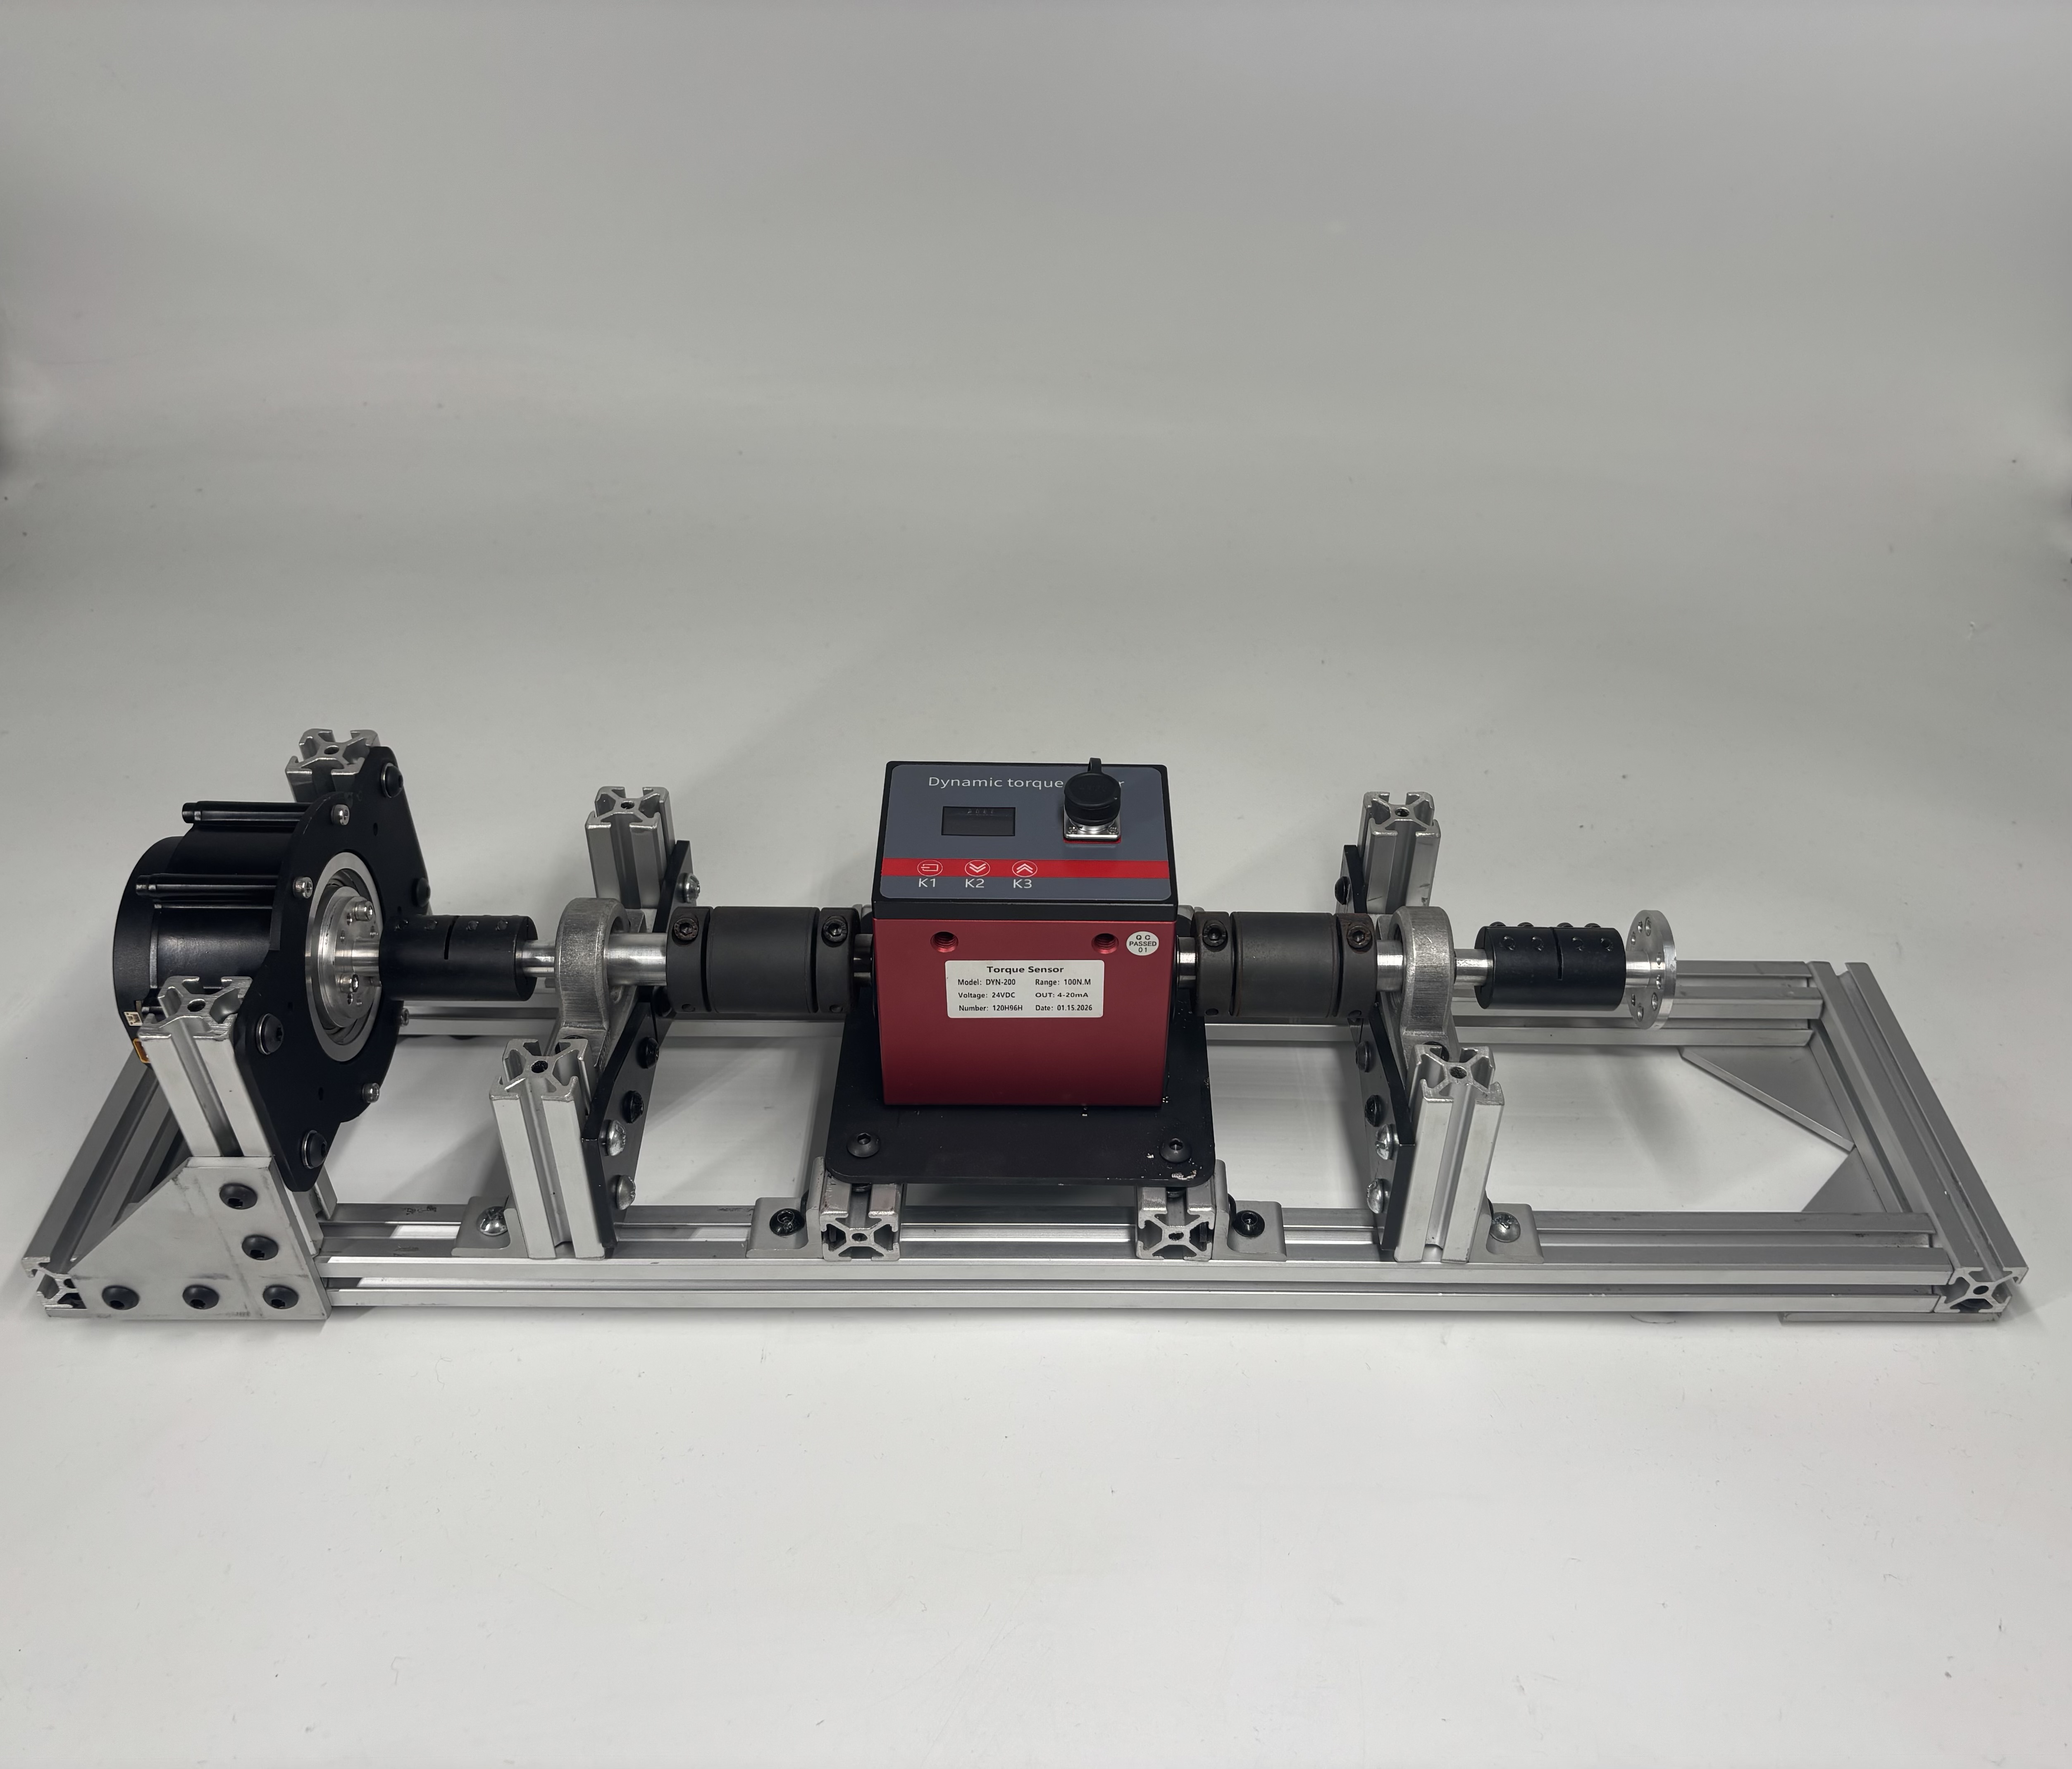
QDD Motor Characterization Machine
A custom test stand for characterizing motor torque, speed, efficiency, and performance under programmable loads.